AthenaZero: A low-inertia, bimanual robot for dynamic manipulation
Andrew S. Morgan, Gregory Xie, Capprin Bass, Rachel Thomasson, Chunpeng Wang, and 21 more authors
Science Robotics, 2026
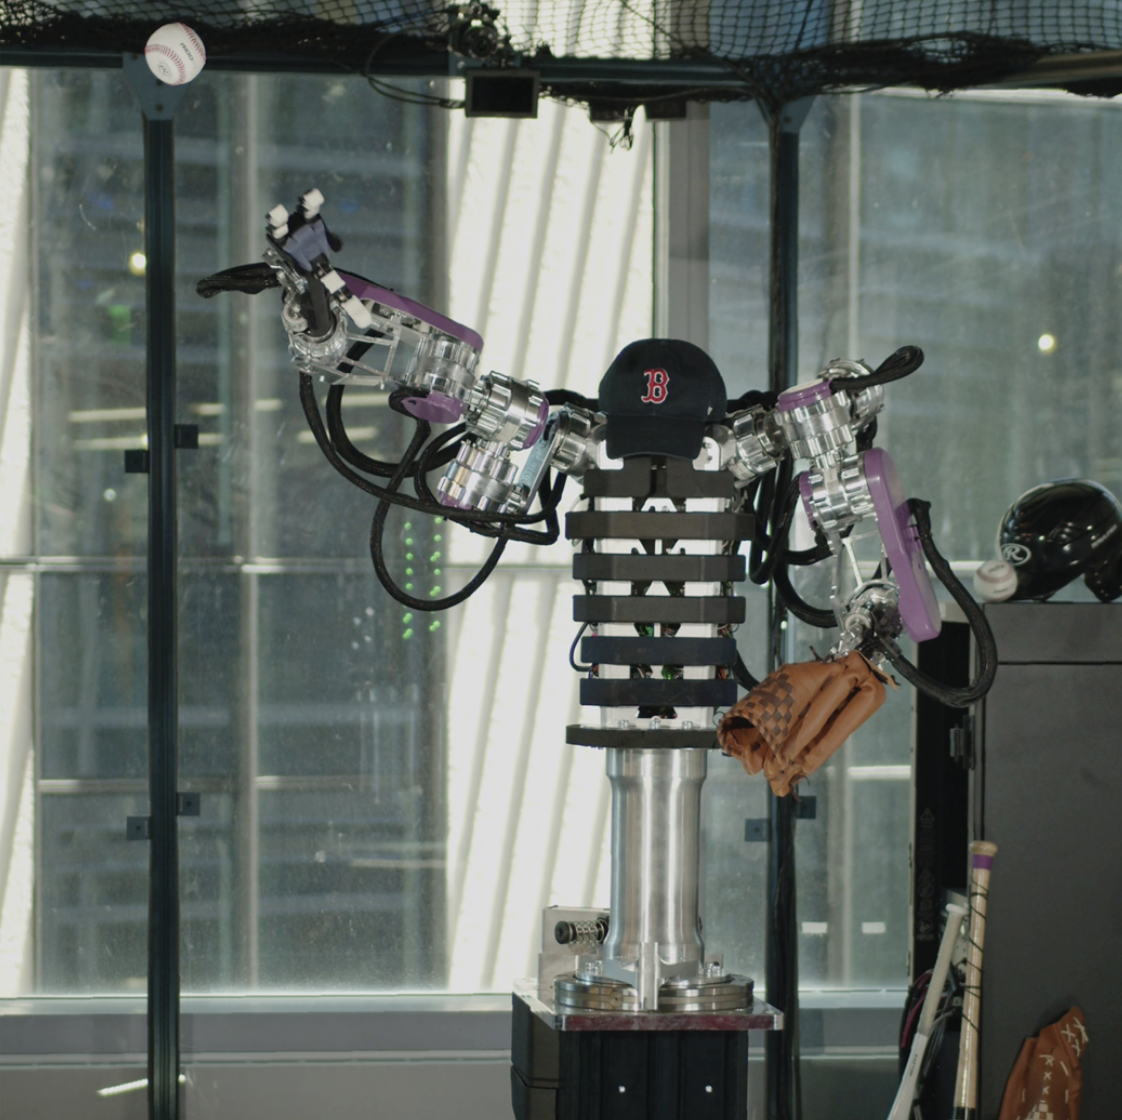
AthenaZero is a bimanual manipulator designed to minimize inertia without compromising control authority. By using quasidirect drive actuation and transmission remotization techniques, the system achieves an effective end-point mass comparable to that of a human, about an order of magnitude less than that of conventional robot manipulators. This characteristic, combined with its inherent torque transparency, makes AthenaZero exceptionally well suited for dynamic manipulation. We describe the methodology that led to this design and demonstrate the robot’s capabilities on three baseball-inspired tasks, throwing, catching, and batting, which showcase complex interactions on human-comparable timescales where milliseconds matter. AthenaZero was capable of throwing at speeds in excess of 30 meters per second, with catching and batting at speeds in excess of 14 meters per second over a short 7.3-meter distance. Batting practice and a game of catch were subsequently performed in robot-to-robot and human-to-robot variations, showcasing the efficacy and adaptability of our system in tasks that require high acceleration. AthenaZero is a bimanual robot designed to minimize inertia and maximize control authority for dynamic manipulation.